Finding
MuJoCo is a physics engine for robots. I asked five models for a grinder hopper dropping 50 coffee beans through an 18 mm throat, with a gate that opens at 1 s. The checker loads each model and measures how it was built.
| Run 1 | Run 2 | Run 3 | |
|---|---|---|---|
| Pareto 26.9 | right | right | right |
| Haiku 5.5 | broken | right | right |
| GPT-6 Luna | broken | built wrong | incomplete |
| DeepSeek 4.1 Flash | no picture | built wrong | nothing |
| Gemini 4 Argon | nothing | nothing | nothing |
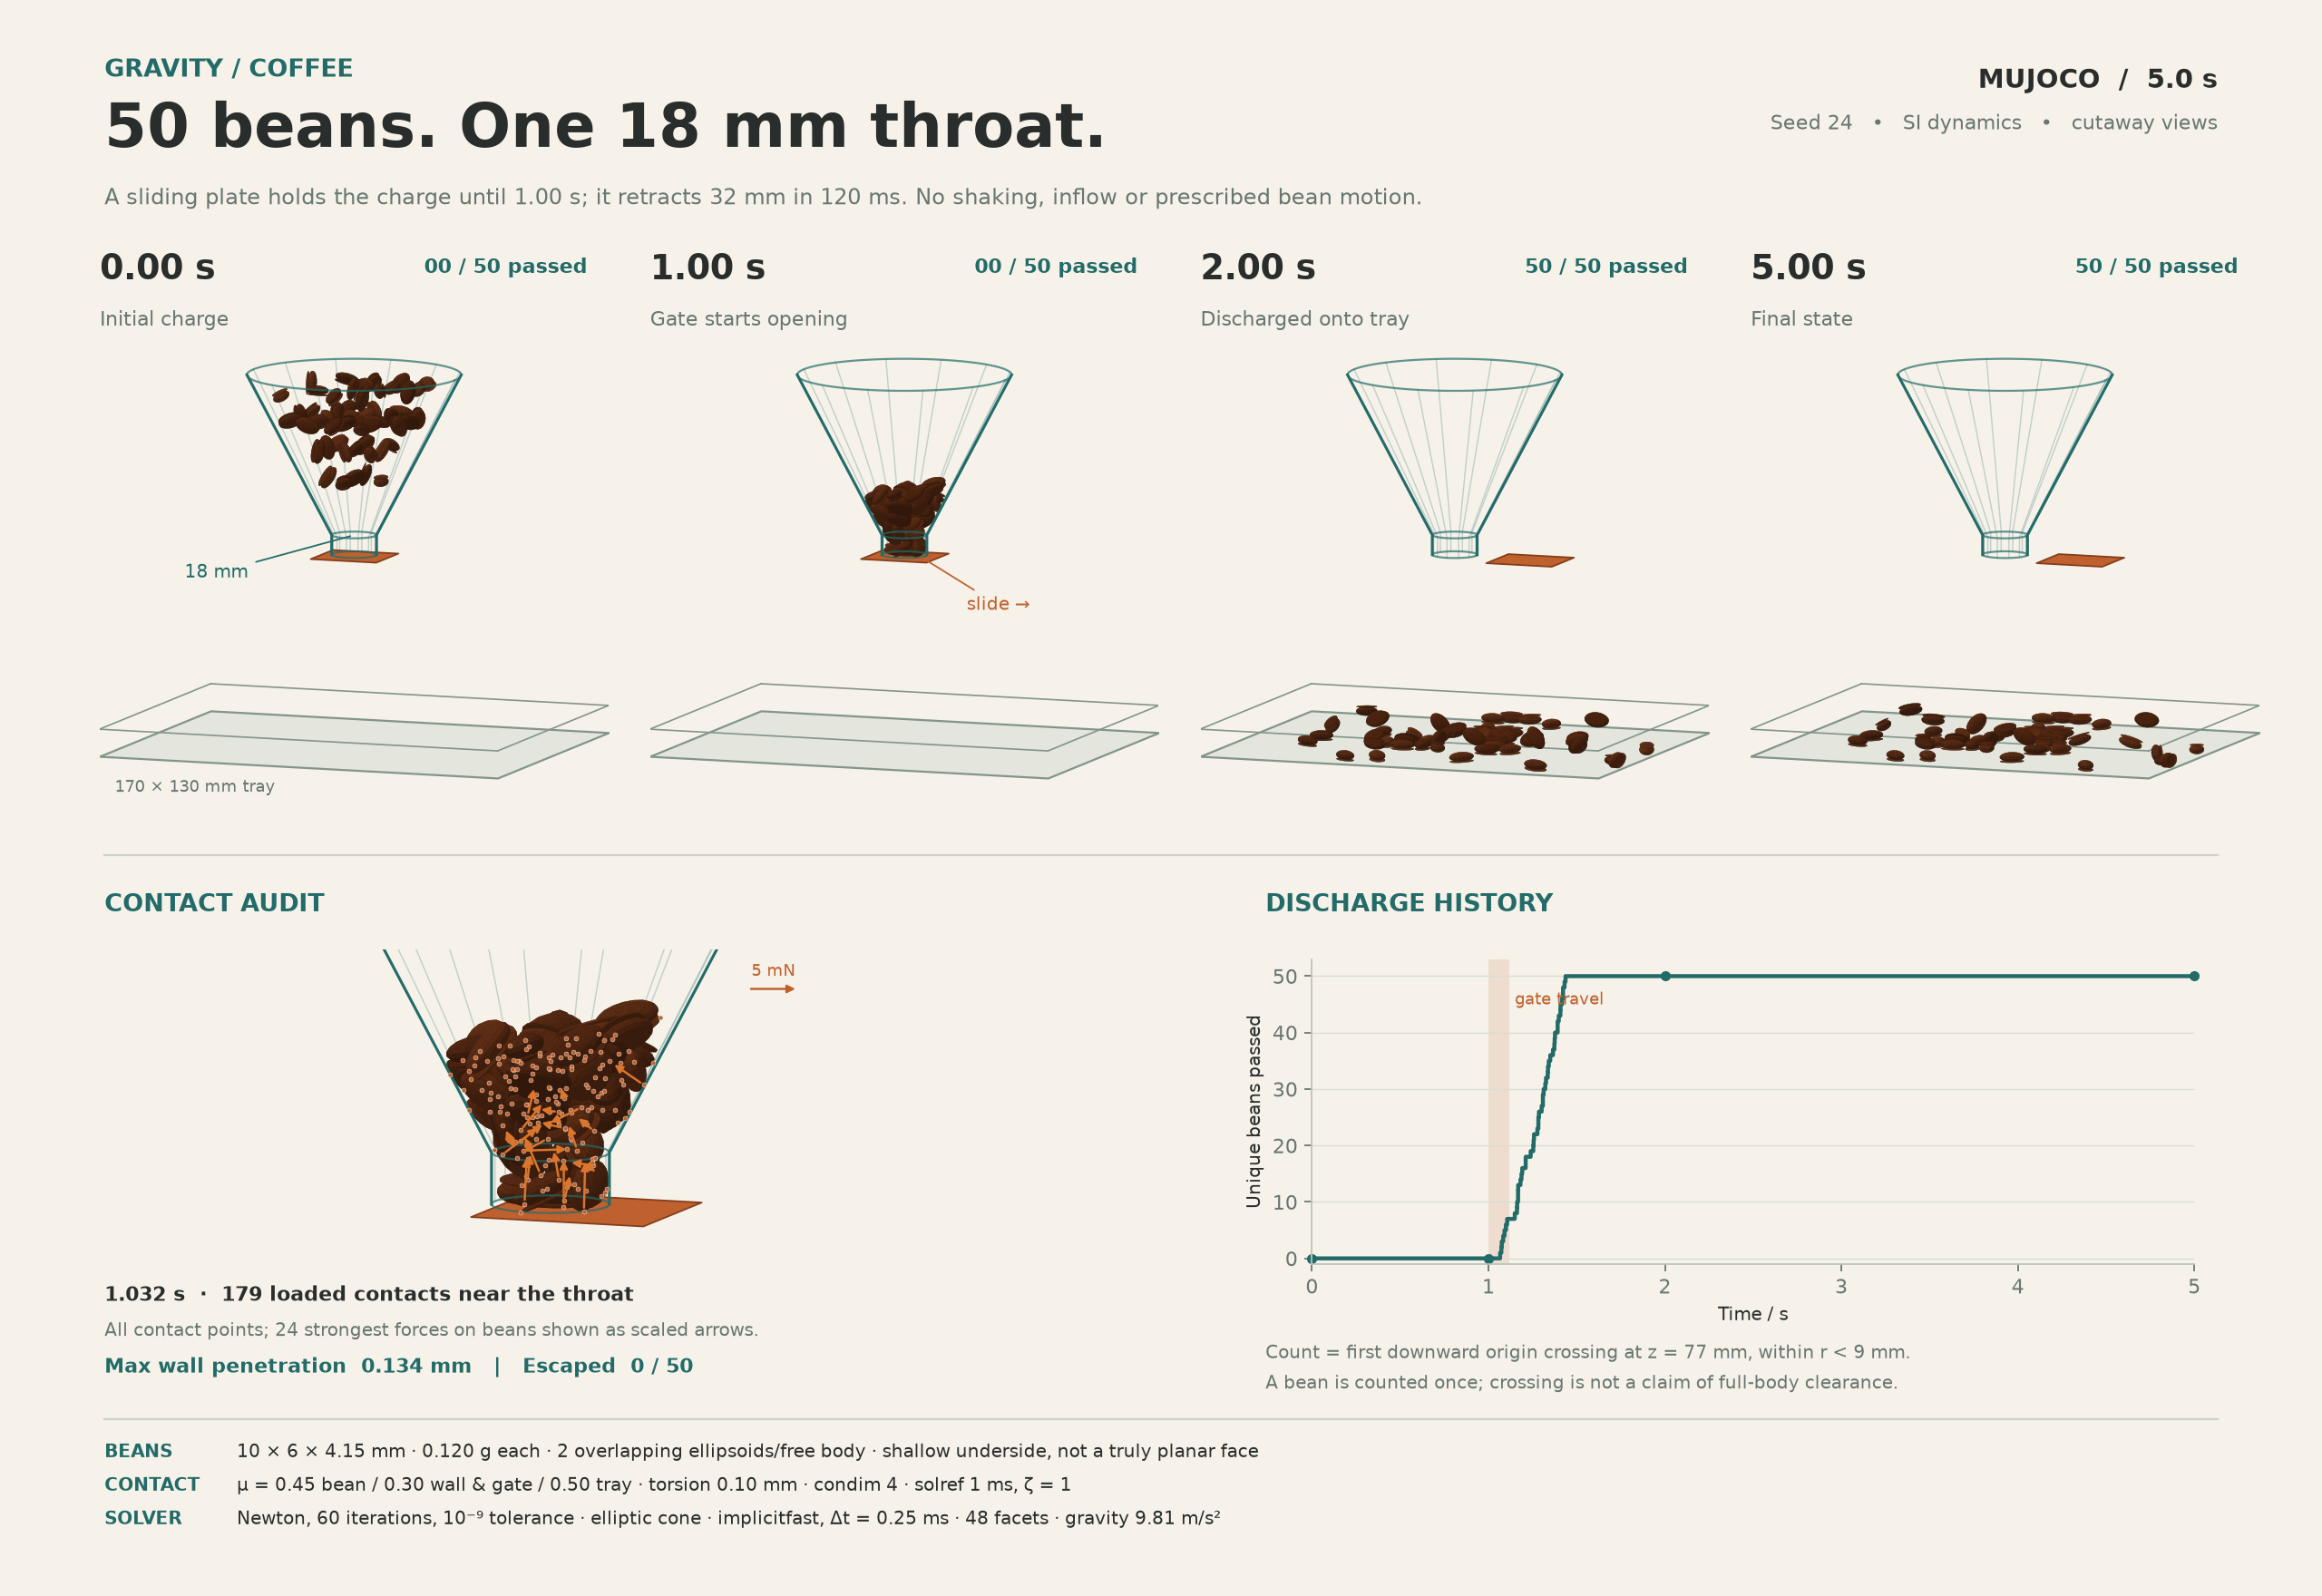
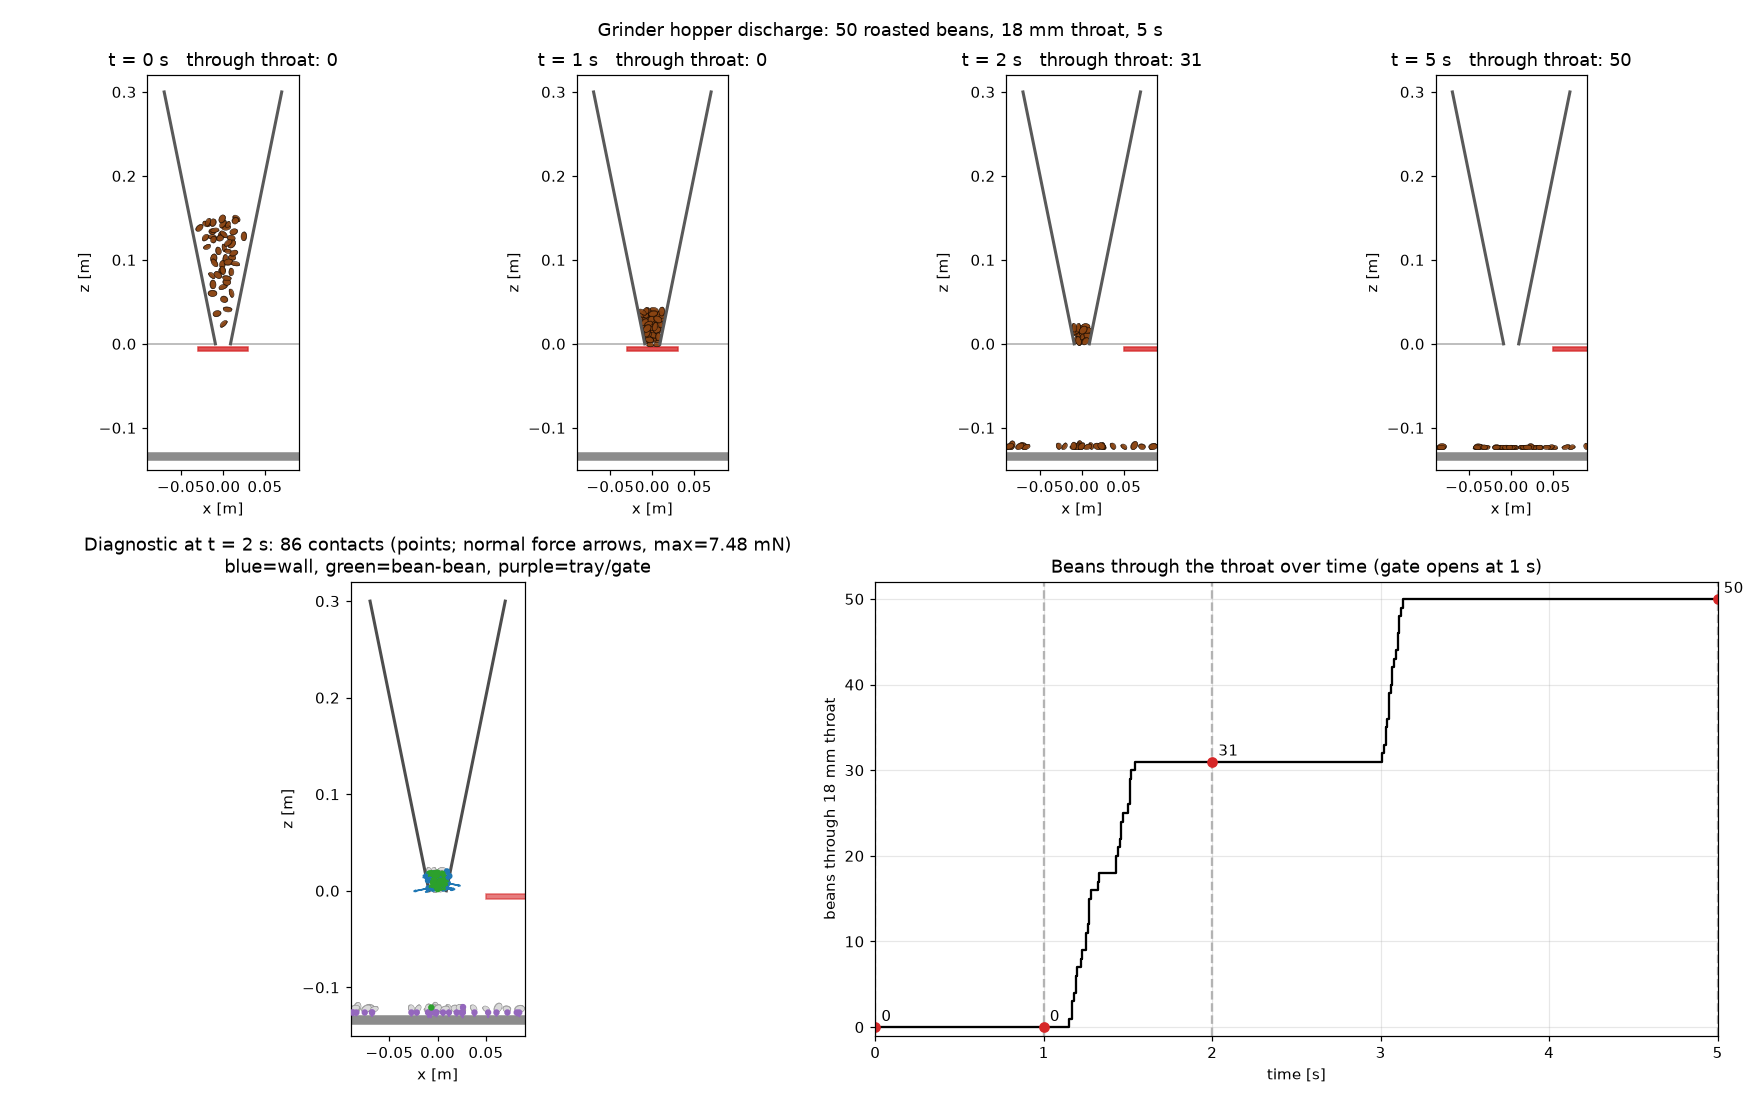
These two pass every measured check, but the beans don't flow as asked, because the checker only measures how the hopper is built, and nothing times the beans. In both, beans a centimetre long wedge across the 18 mm throat. Haiku's own printout said 40 were stuck. Pareto drew the nicer figures, but Haiku is cheaper.
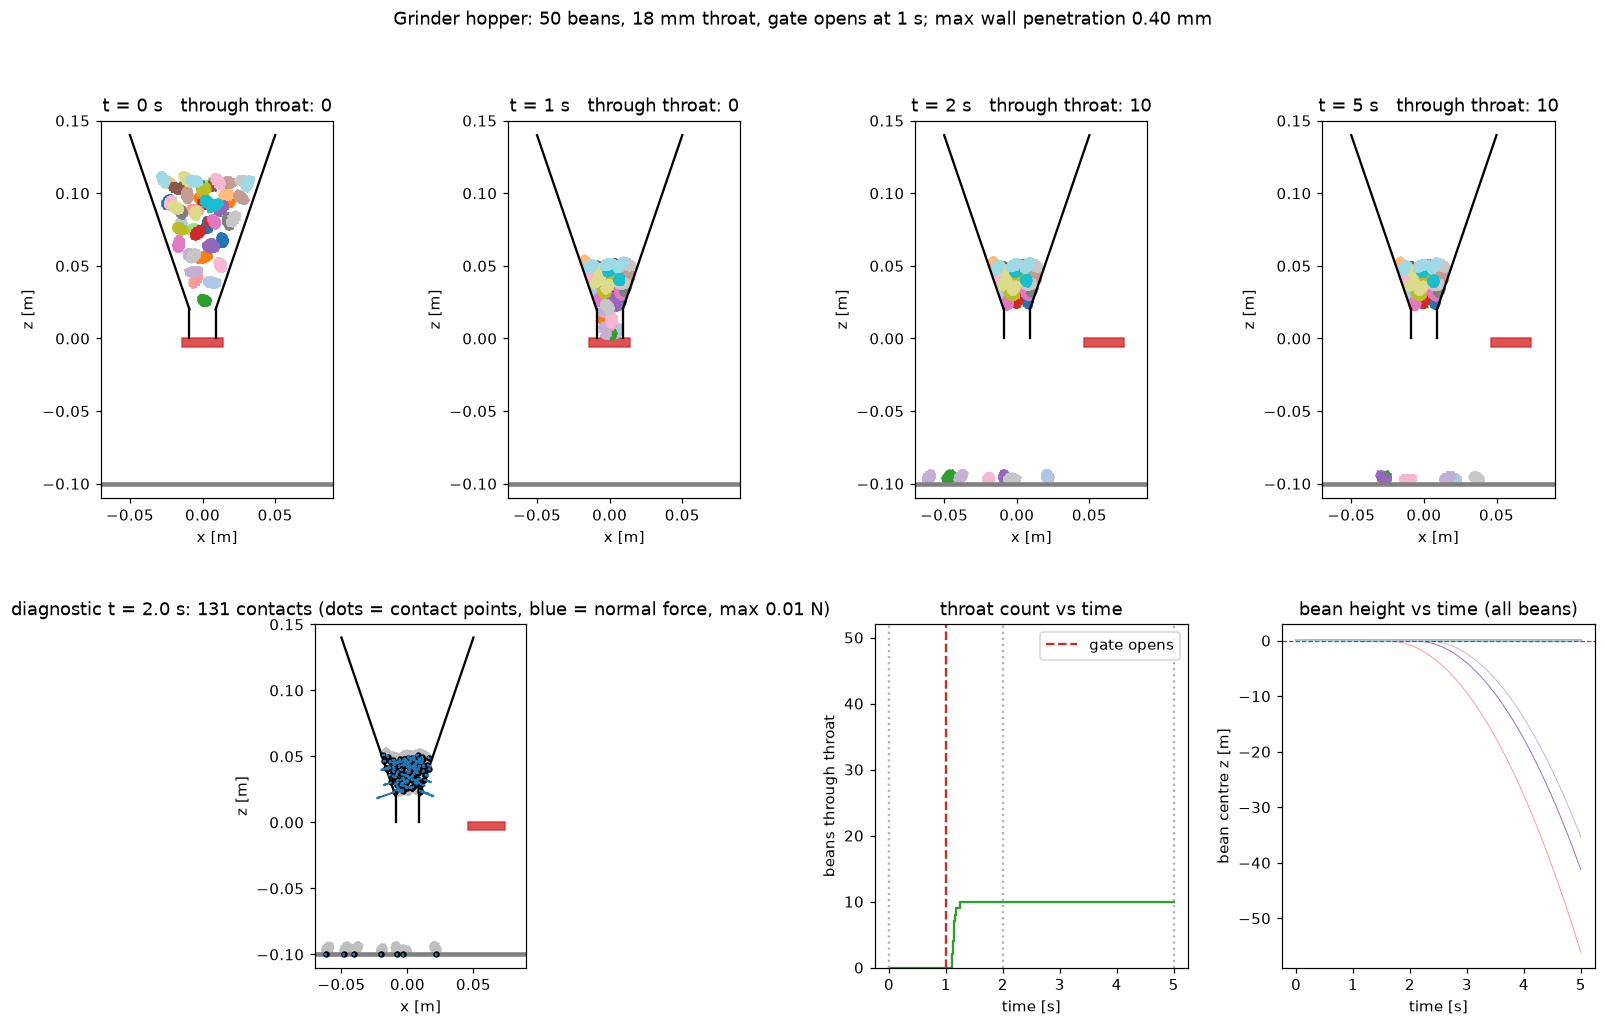
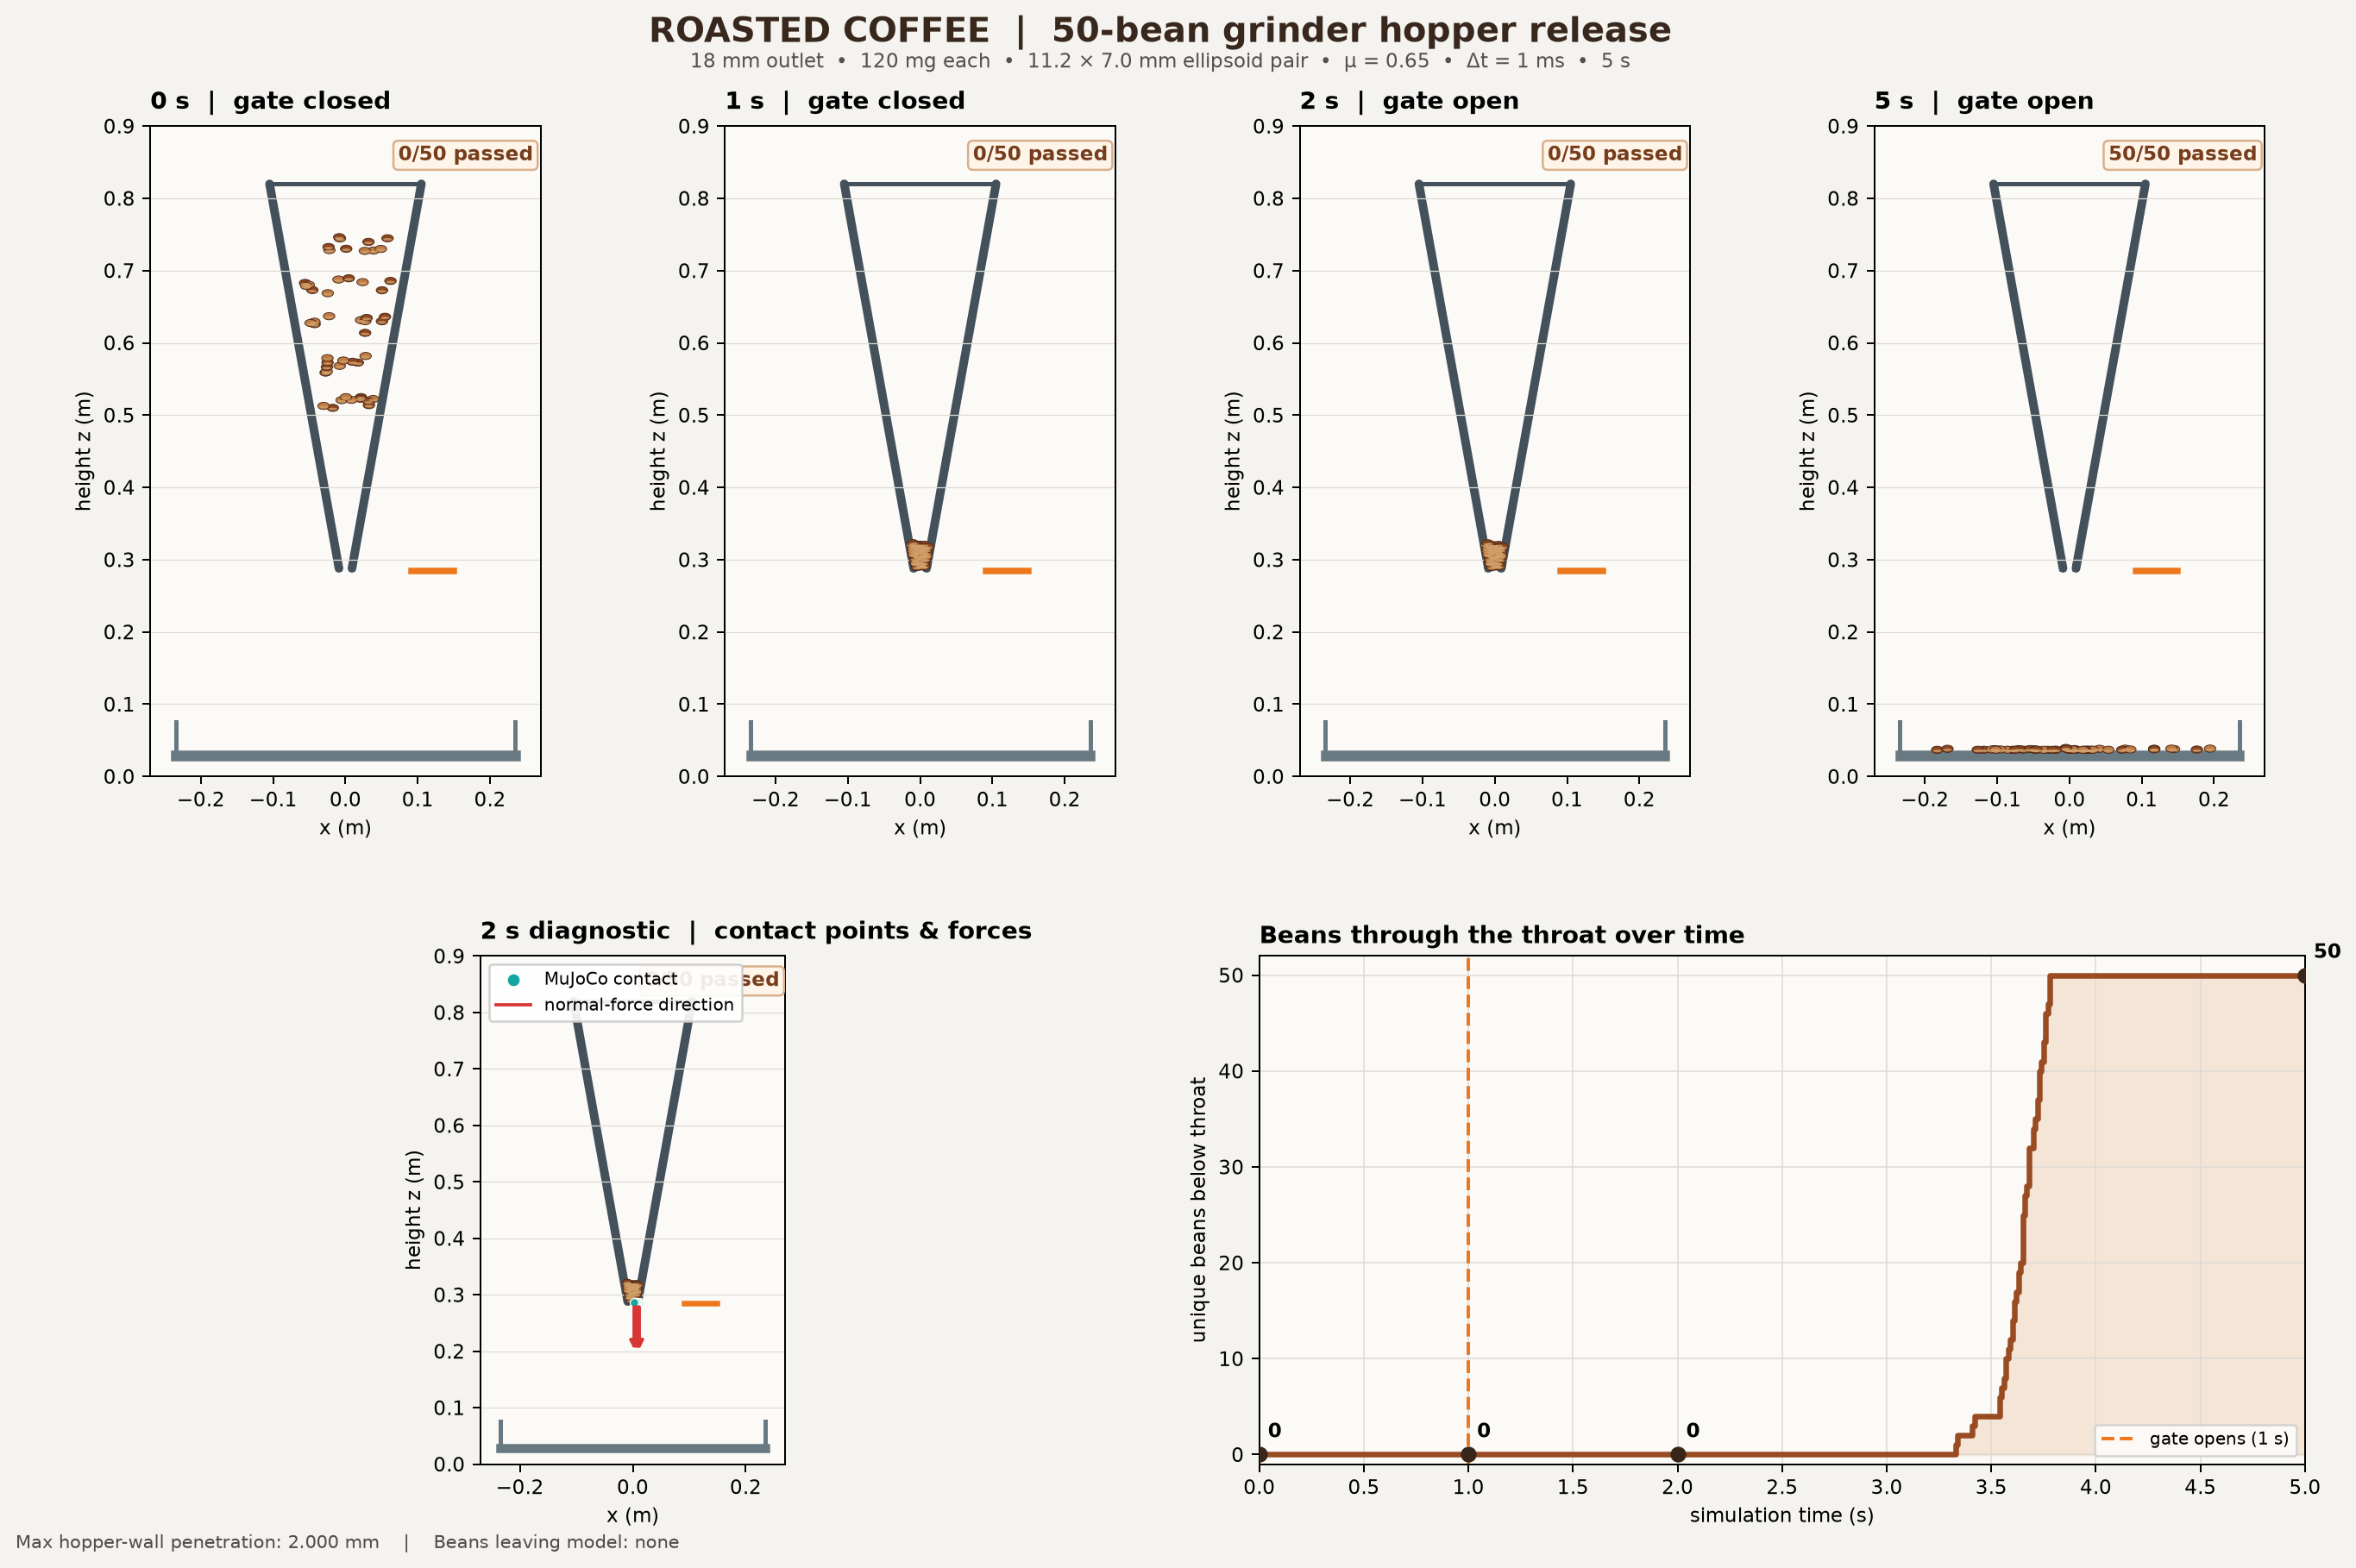
These two fail on how they were built.
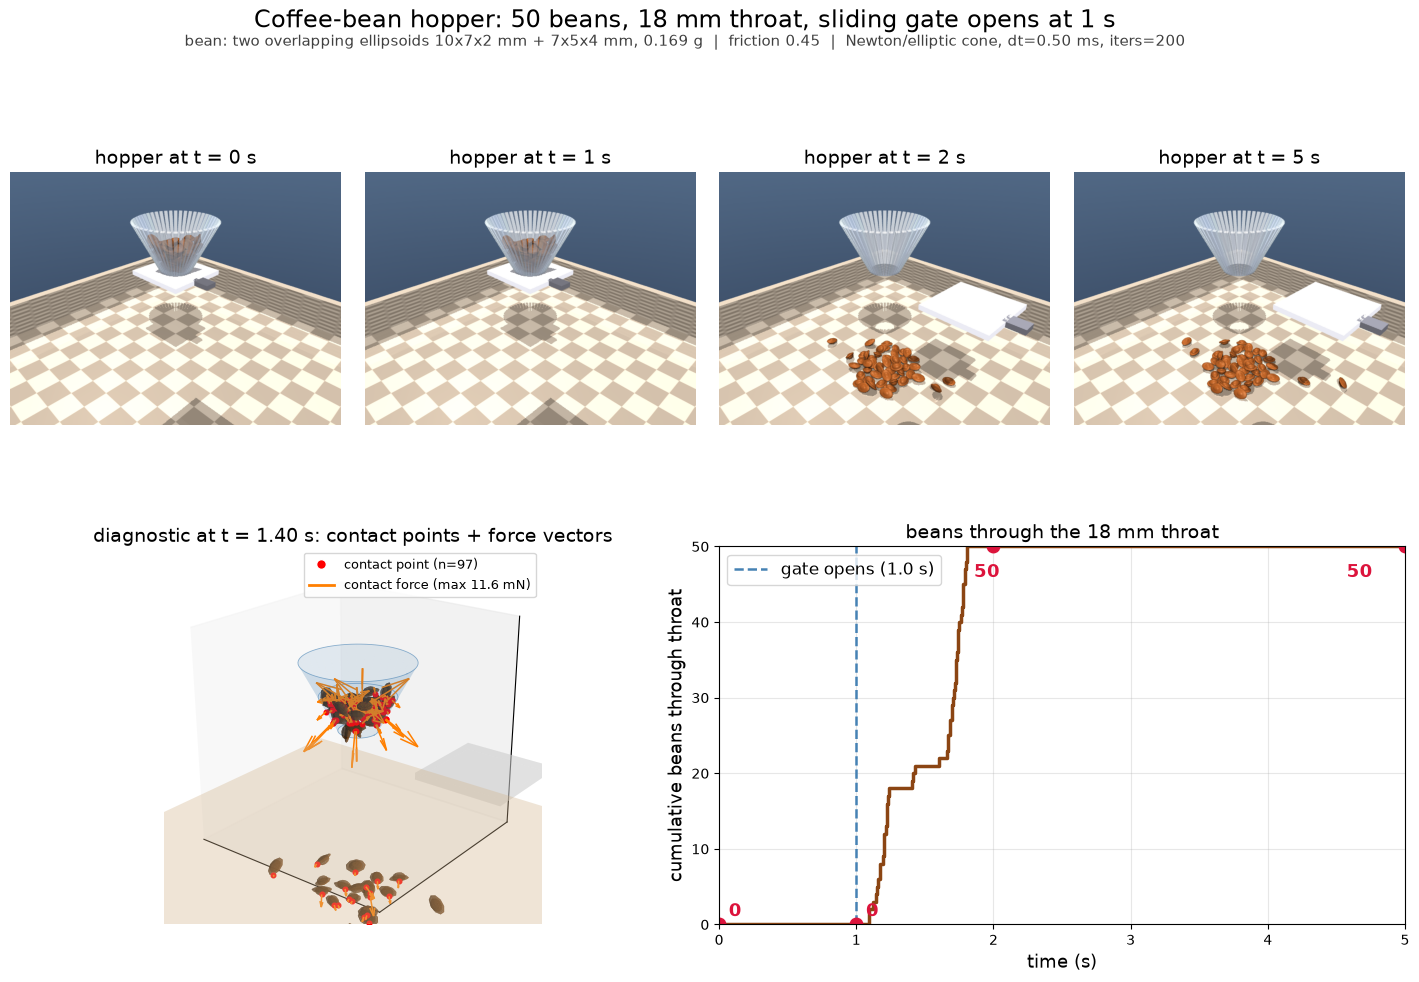
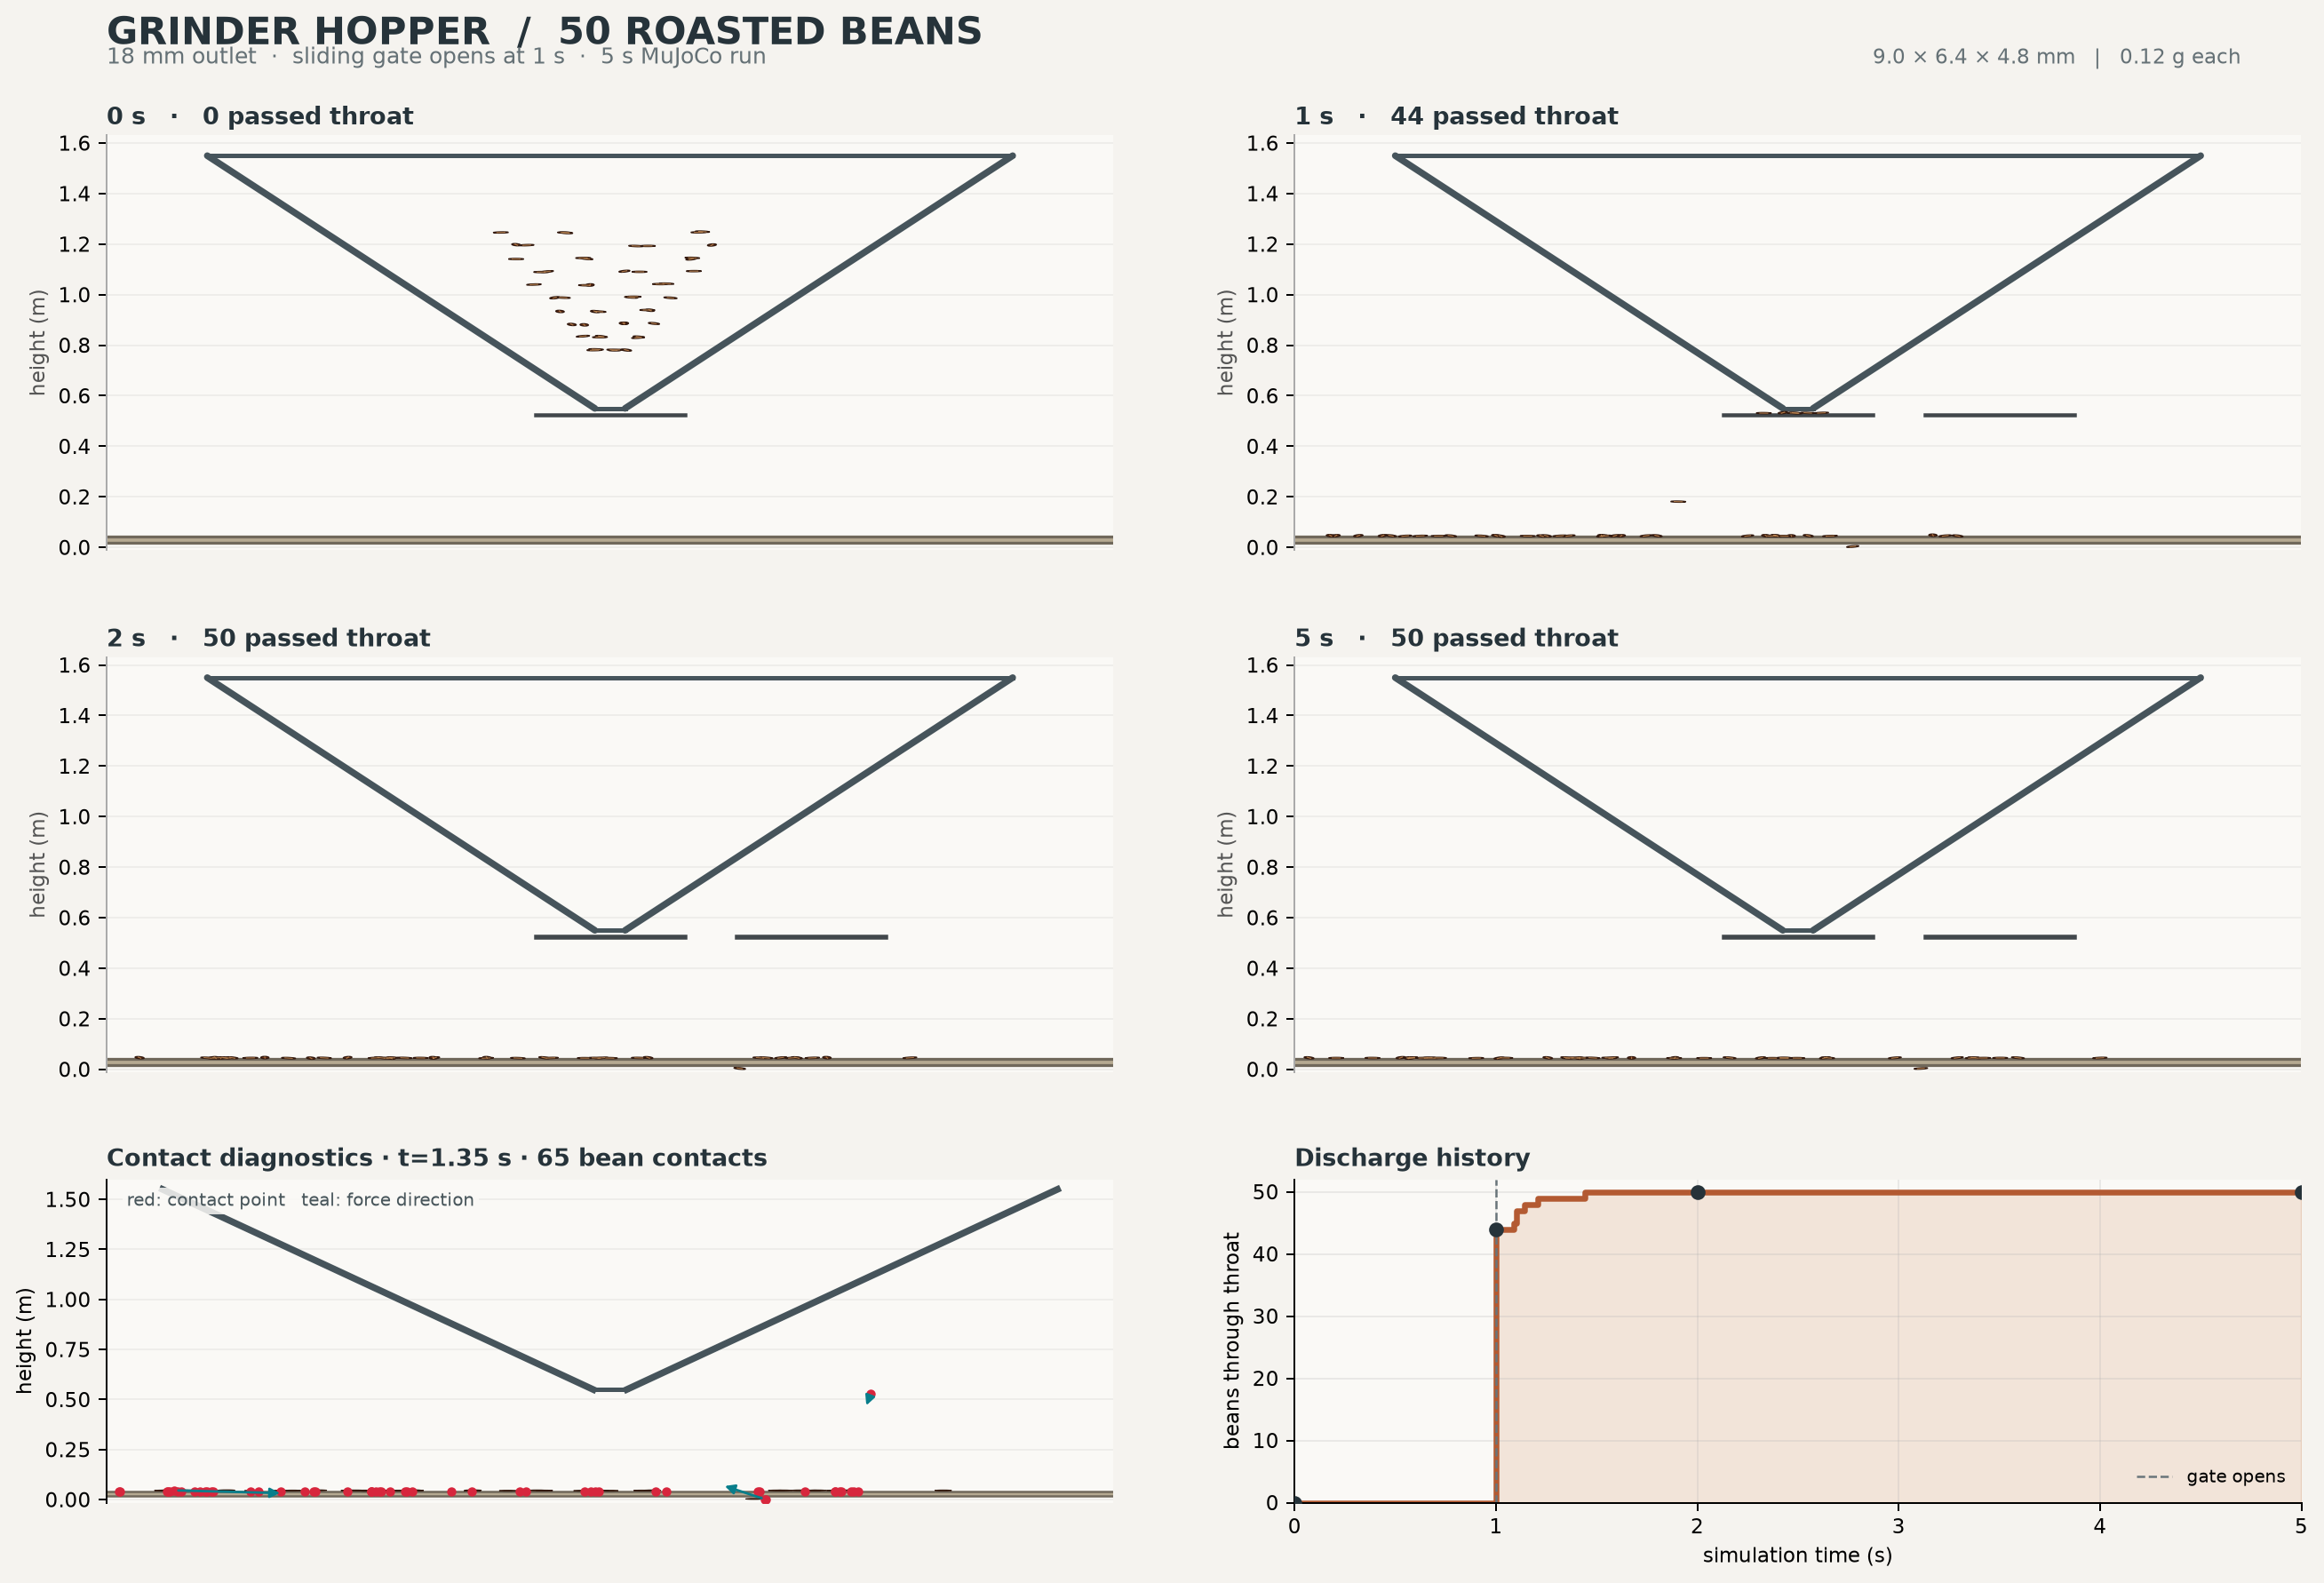
Luna's second run crashed on its last round, and DeepSeek's first ran out of time before saving its picture. Gemini 4 Argon spent its twelve minutes testing the physics in scratch scripts. Maybe in the future, I can remove the 12 mins cap, but for now, I still want things to be completed in a decent time if possible.
The 14 runs cost $1.73. Gemini’s three were $0.54 of it.